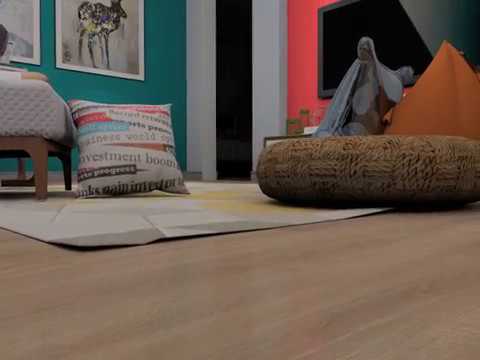
Ground Robot
Number of images: 1600
Size: 587M/1.4G
Reported frame rate: 20Hz
Reported duration: 80 secs
Imperial College London

Benchmarking mapping and motion estimation algorithms is established practice in robotics and computer vision. As the diversity of datasets increases, in terms of the trajectories, models and scenes, it becomes a challenge to select datasets for a given benchmarking purpose. This paper addresses this concern by developing novel metrics to evaluate trajectories and the environments without relying on any SLAM or motion estimation algorithm. The metrics, which so far have been missing in the research community, can be applied to the plethora of datasets that exist. The proposed metric is a general metric and can be used for other purposes. To demonstrate the effectiveness of the metric in robotic applications, the metric has also been applied to run-time SLAM adaptation. Additionally, to improve the robotics SLAM benchmarking, the paper presents a new dataset for visual localization and mapping algorithms. A broad range of real-world trajectories is used in very high-quality scenes and a rendering framework to create a set of synthetic datasets with ground-truth trajectory and dense map which are representative of key SLAM applications such as virtual reality (VR), micro aerial vehicle (MAV) flight, and ground robotics.
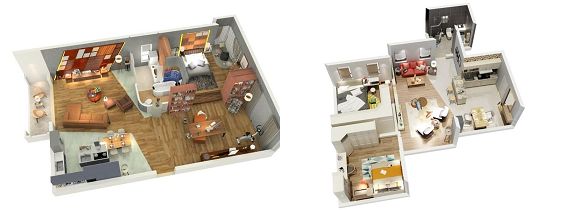
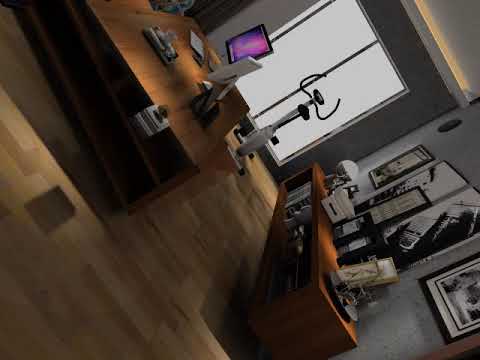
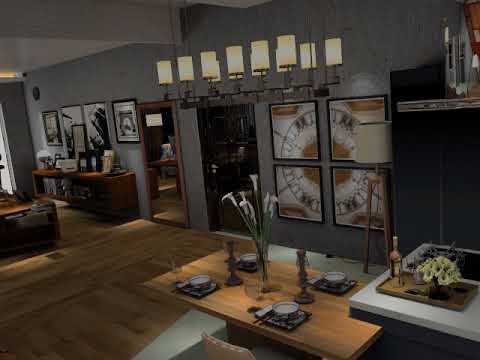
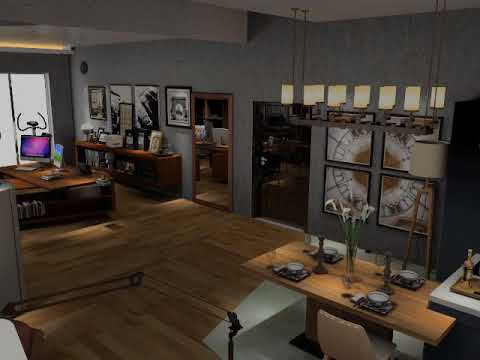
In this work, we render ground-truth data on two high resolution scenes provided by kujiale.com. Scene Diamond (left, 3,539,795 vertices and 6,951,971 faces) particularly represents a wide interior space with low light condition whilst Deer (right, 6,863,205 vertices and 13,617,380 faces) shows a crowded living room with multiple small objects occluded from each other.
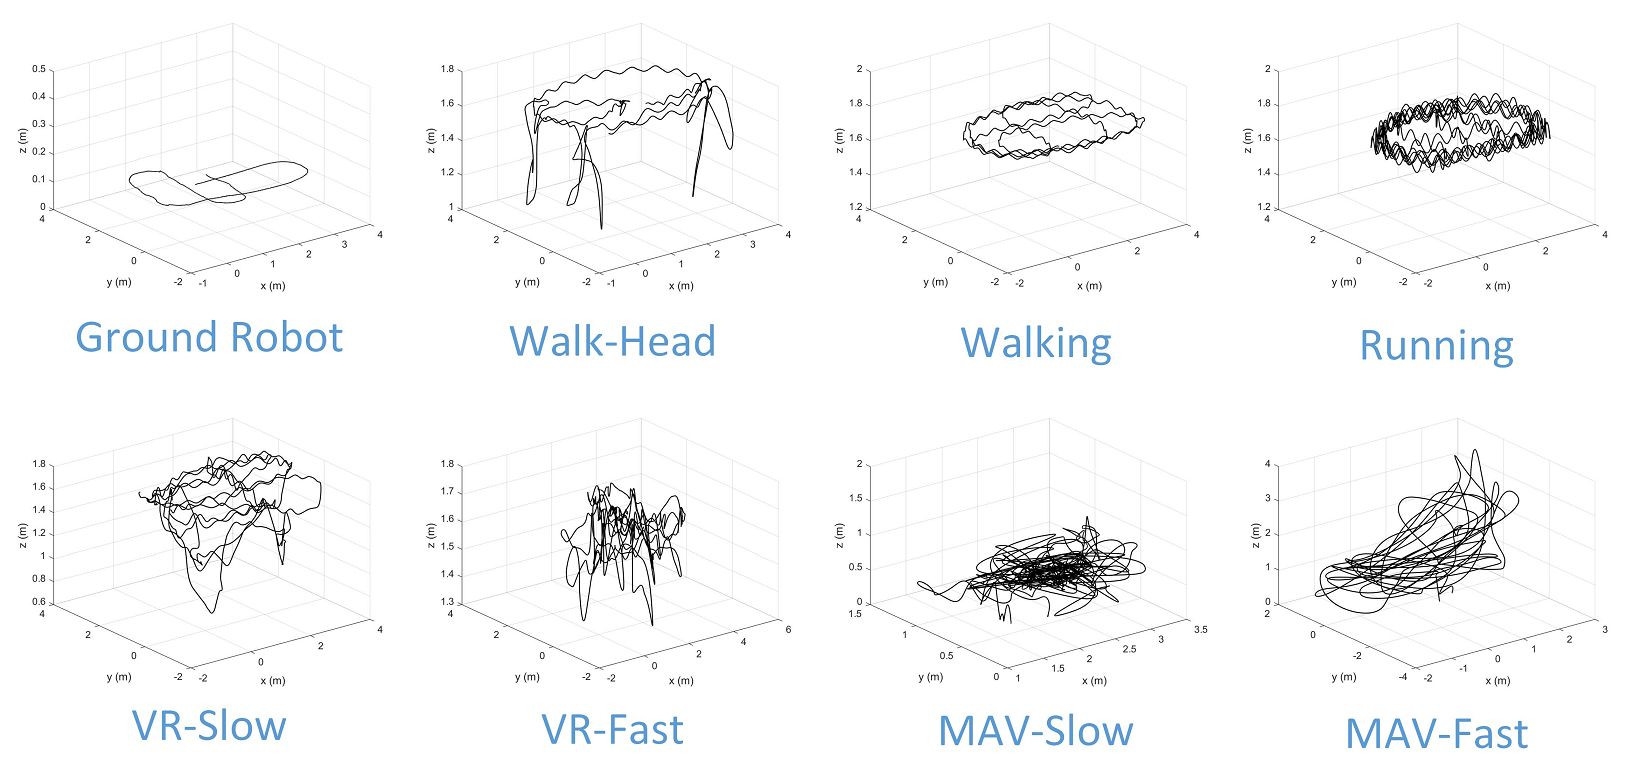
Counts, frame rates and durations below reproduce the original release description. Timestamp units and pose conventions have not been independently verified. Do not infer an image-to-pose alignment from these descriptions.
Number of images: 1600
Size: 587M/1.4G
Reported frame rate: 20Hz
Reported duration: 80 secs
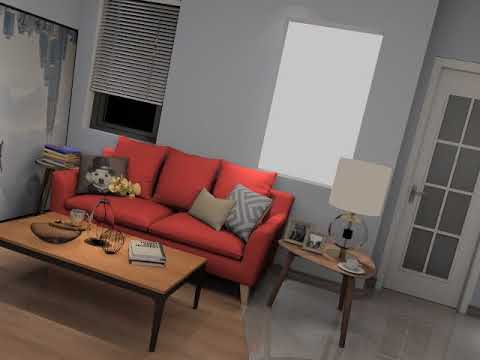
Number of images: 1308
Size: 603M/1.3G
Reported frame rate: 20Hz
Reported duration: 65 secs
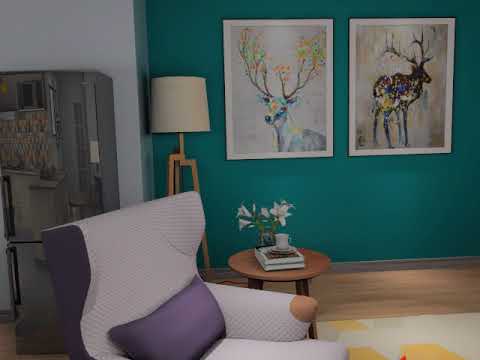
Number of images: 1281
Size: 586M/1.3G
Reported frame rate: 20Hz
Reported duration: 60 secs
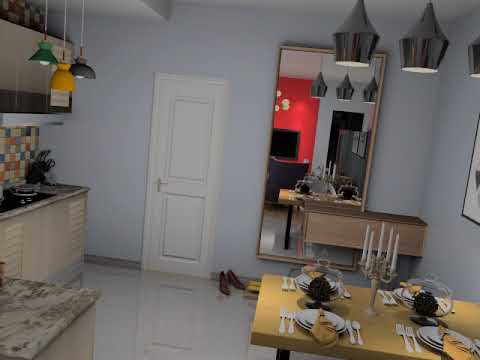
Number of images: 569
Size: 259M/582M
Reported frame rate: 30Hz
Reported duration: 17 secs
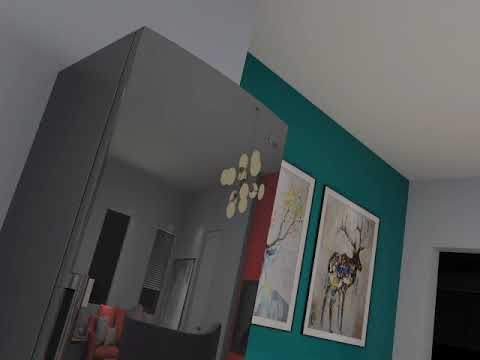
Number of images: 2083
Size: 1.0G/2.1G
Reported frame rate: 30Hz
Reported duration: 62.5 secs
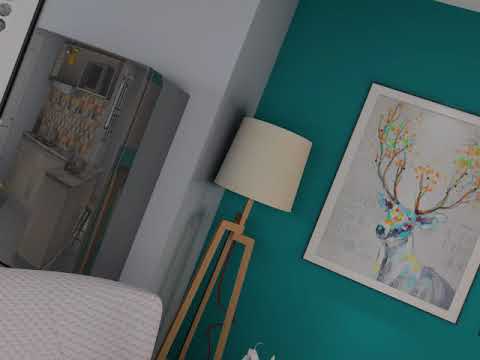
Number of images: 1228
Size: 581M/1.2G
Reported frame rate: 20Hz
Reported duration: 60 secs
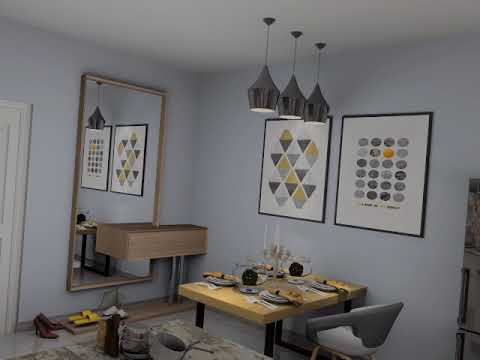
Number of images: 2001
Size: 1.2G/2.0G
Reported frame rate: 20Hz
Reported duration: 100 secs
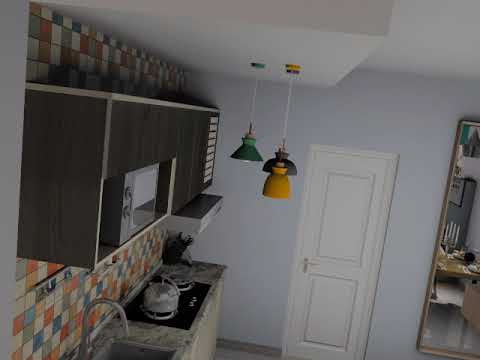
Number of images: 2050
Size: 1.0G/2.0G
Reported frame rate: 20Hz
Reported duration: 100 secs
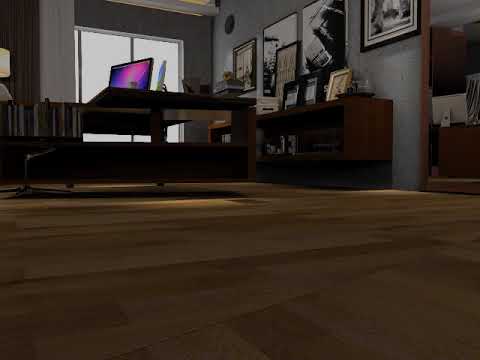
Number of images: 1600
Size: 673M/1.4G
Reported frame rate: 20Hz
Reported duration: 80 secs
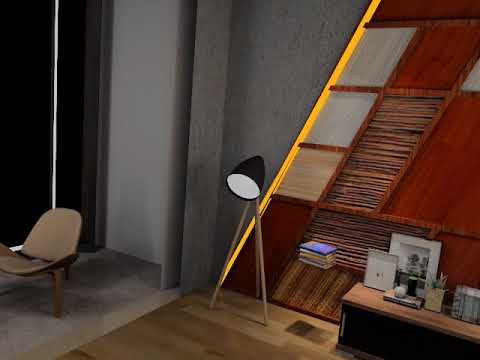
Number of images: 1308
Size: 722M/1.2G
Reported frame rate: 20Hz
Reported duration: 65 secs
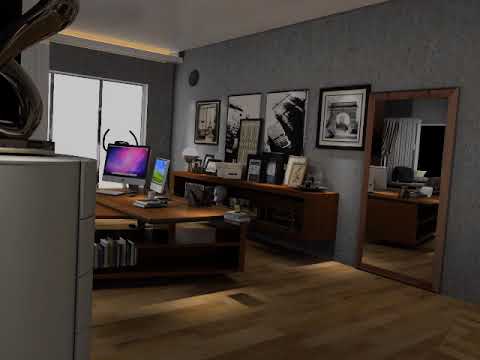
Number of images: 1281
Size: 664M/1.2G
Reported frame rate: 20Hz
Reported duration: 60 secs
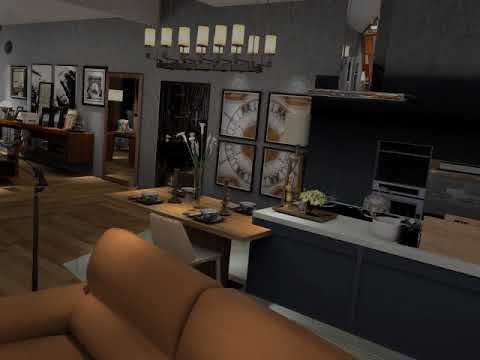
Number of images: 569
Size: 309M/548M
Reported frame rate: 30Hz
Reported duration: 17 secs
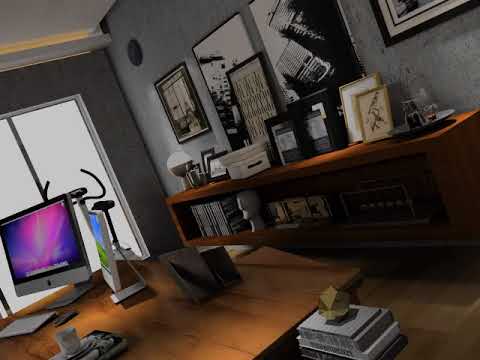
Number of images: 2083
Size: 1.0G/2.0G
Reported frame rate: 30Hz
Reported duration: 62.5 secs
Number of images: 1228
Size: 718M/1.2G
Reported frame rate: 20Hz
Reported duration: 60 secs
Number of images: 2001
Size: 1.1G/1.9G
Reported frame rate: 20Hz
Reported duration: 100 secs
Number of images: 2050
Size: 1.0G/2.0G
Reported frame rate: 20Hz
Reported duration: 100 secs
The following results are reproduced from the original release, not a new experiment.
| No. | Model | Trajectory | ATE [m] | RPE [m] | Tracked [%] |
|---|---|---|---|---|---|
| 1 | Deer | Ground Robot | 0.01452 | 0.01104 | 59 |
| 2 | Deer | Walk-Head | 0.2074 | 0.05496 | 99 |
| 3 | Deer | Walk | 0.08640 | 0.1454 | 100 |
| 4 | Deer | Run | 0.04650 | 0.0672 | 64 |
| 5 | Deer | VR slow | 0.6152 | 0.06583 | 98 |
| 6 | Deer | VR fast | 0.9051 | 0.3117 | 40 |
| 7 | Deer | MAV slow | 0.0102 | 0.0929 | 100 |
| 8 | Deer | MAV fast | 0.9525 | 0.0681 | 96 |
| 9 | Diamond | Ground Robot | 0.2112 | 0.0181 | 100 |
| 10 | Diamond | Walk-Head | 0.0187 | 0.0482 | 100 |
| 11 | Diamond | Walk | 0.0479 | 0.0530 | 100 |
| 12 | Diamond | Run | 0.1408 | 0.0750 | 100 |
| 13 | Diamond | VR slow | 0.0192 | 0.0667 | 100 |
| 14 | Diamond | VR fast | 1.354 | 0.3113 | 57 |
| 15 | Diamond | MAV slow | 0.0086 | 0.0758 | 100 |
| 16 | Diamond | MAV fast | 0.0090 | 0.1162 | 100 |
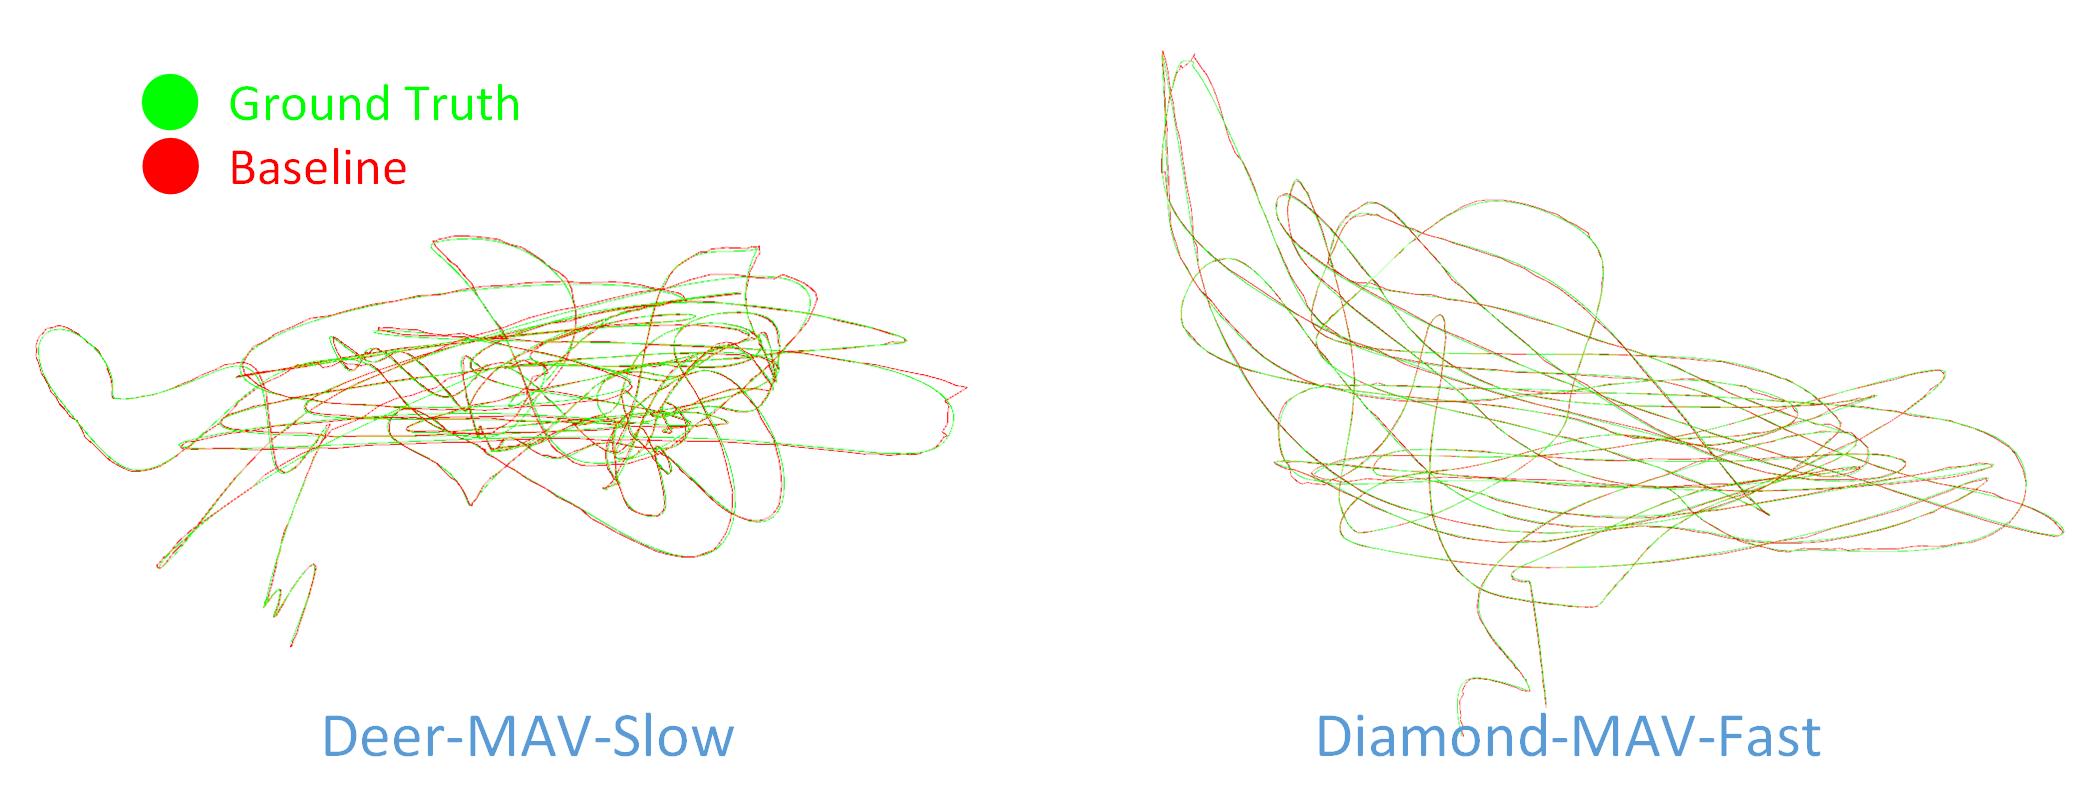
Absolute trajectory error (ATE), relative pose error (RPE), and tracked frames for ORBSLAM2.0 in RGB-D mode.
The scenes, images, video and related ground truth data presented within this page is intended for research use ONLY.
This research is supported by Engineering and Physical Sciences Research Council (EPSRC), grant references EP/K008730/1 and EP/N018494/1. We also thank Dr. Rui Tang from kujiale.com for providing us the scenes Diamond and Deer.
@inproceedings { Characterizing19,
      author = {Saeedi, Sajad and Carvalho, Eduardo D C and Li, Wenbin and Tzoumanikas, Dimos and Leutenegger, Stefan and Kelly, Paul H J and Davison, Andrew J},
   booktitle = { International Conference on Robotics and Automation (ICRA) },
       title = { Characterizing Visual Localization and Mapping Datasets },
       pages = { 6699--6705 },
        year = { 2019 },
organization = { IEEE }
}
© Pering Laboratory
is affiliated with AI&ML, and Visual Intelligence groups,
Department of Computer Science, University of Bath, UK.
This website is built on Jekyll with the theme of Allan Lab.